Ali HakamControls / Mechanical / Systems

Robotics and Controls Portfolio

Available January 1, 2027

Controls. Mechanical design. Systems integration.

Selected work ↓

Selected work

01–05
ZIMA prototype footage. Water test and project presentation.

01 / Subvision Robotics

ZIMA
subsea rover

Organisms growing on ship hulls increase drag and fuel use. We’re developing a robot that combines magnetic swerve drive with UV-C treatment to prevent that buildup.

I lead the team and work on the chassis, subsea gearboxes, and embedded actuation software.

  • Embedded control
  • Mechanical design

Prototype in development

Camera feedback and two servos balance the ball on the plate.

02 / Feedback control

Ball-and-plate
control

I built the platform, tracked the ball with a camera, and wrote the controllers that move the plate.

The project connects a dynamics model to real hardware, with PID and state-feedback implementations and a discrete LQR design.

  • Python / OpenCV
  • PID / State feedback / LQR

Hardware demonstration

05 / Team leadership · 2016–2020

FIRST Robotics Competition

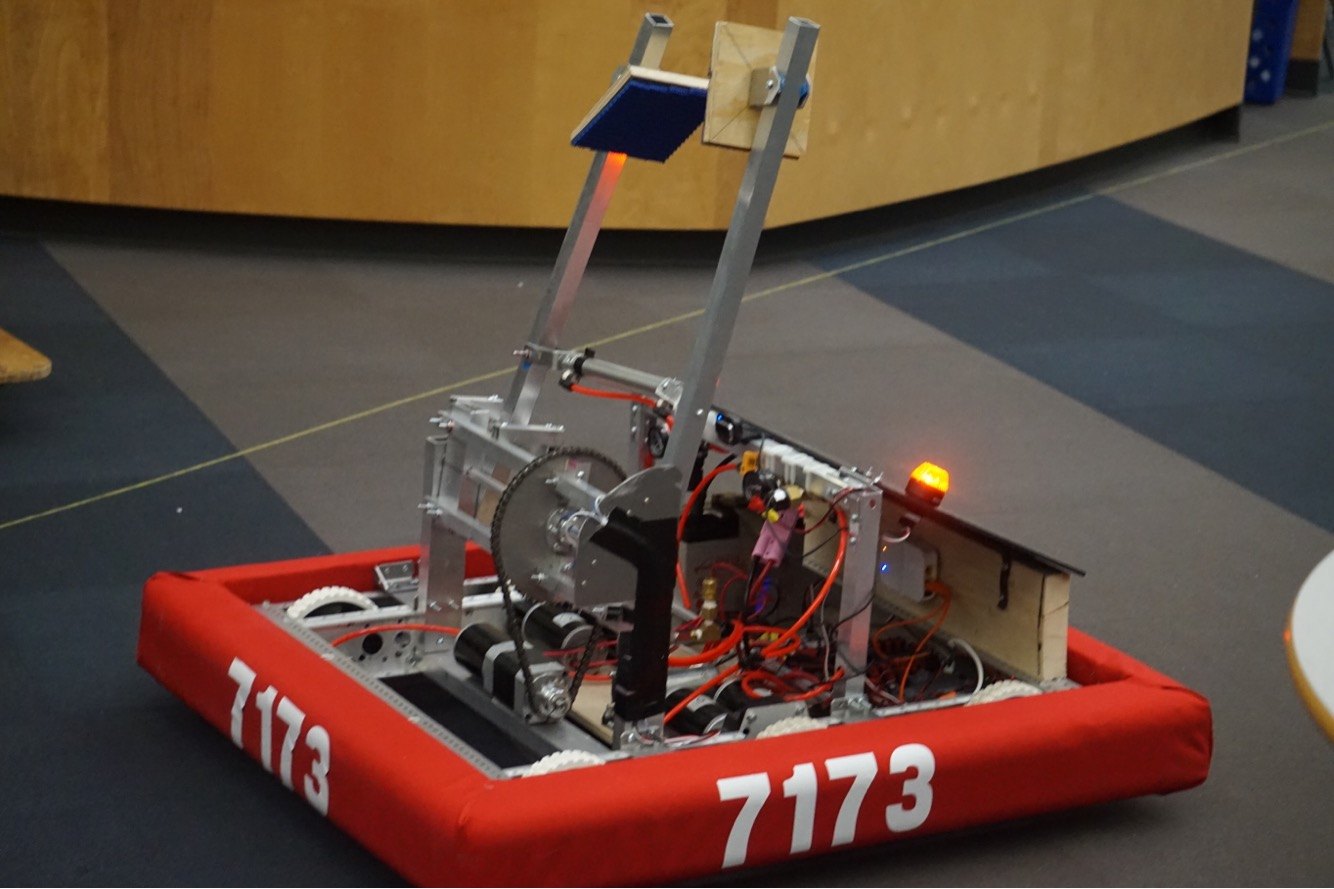
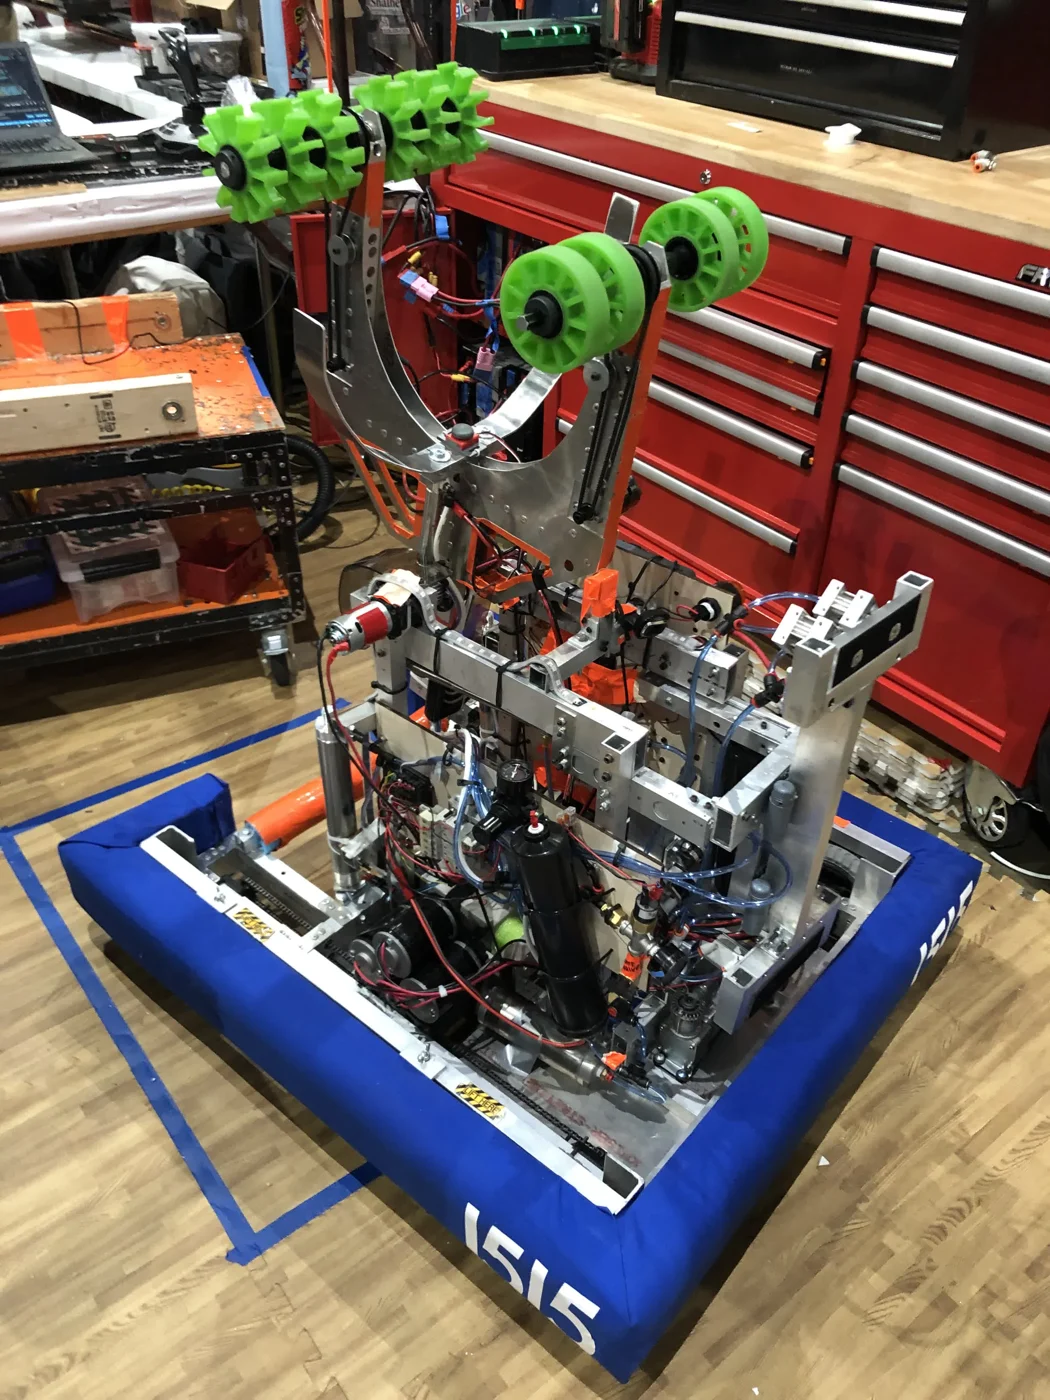
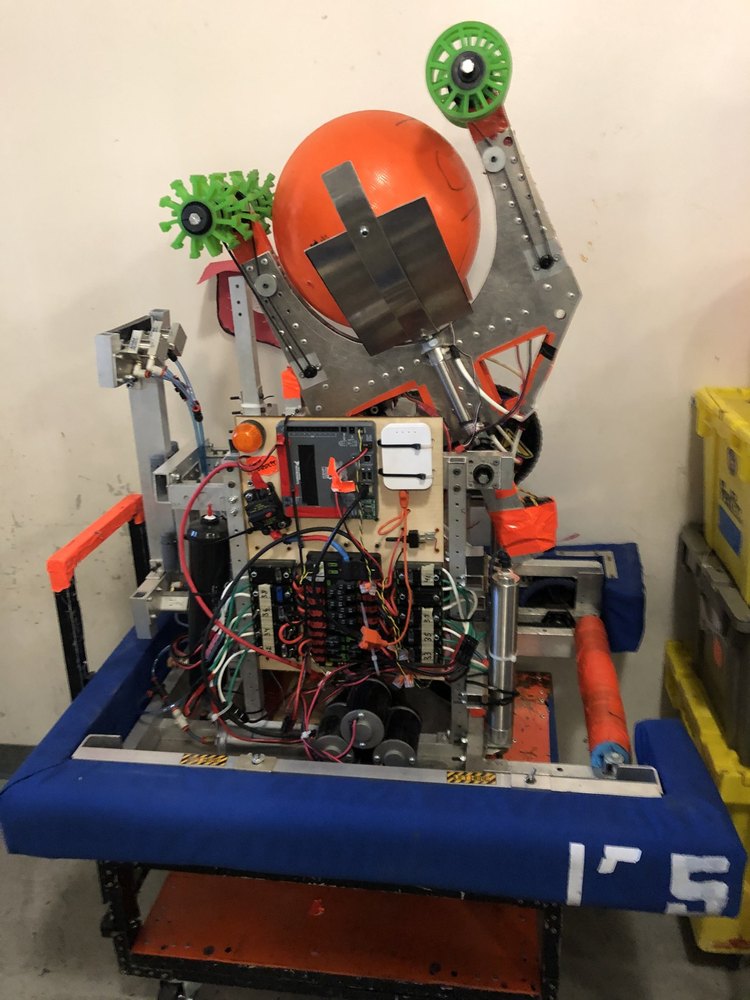
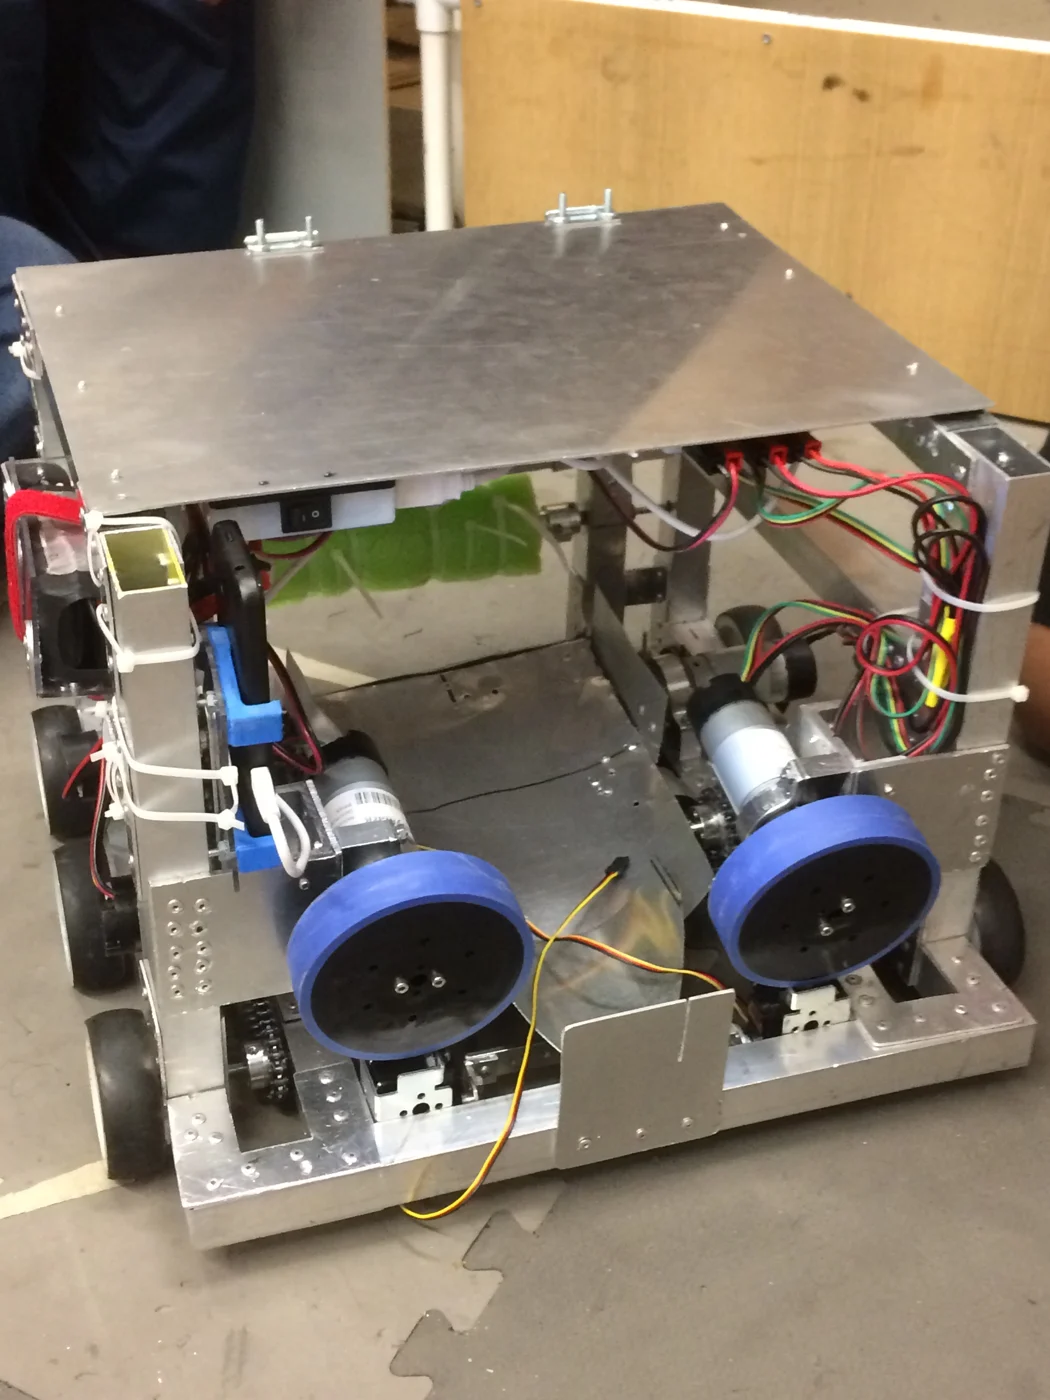
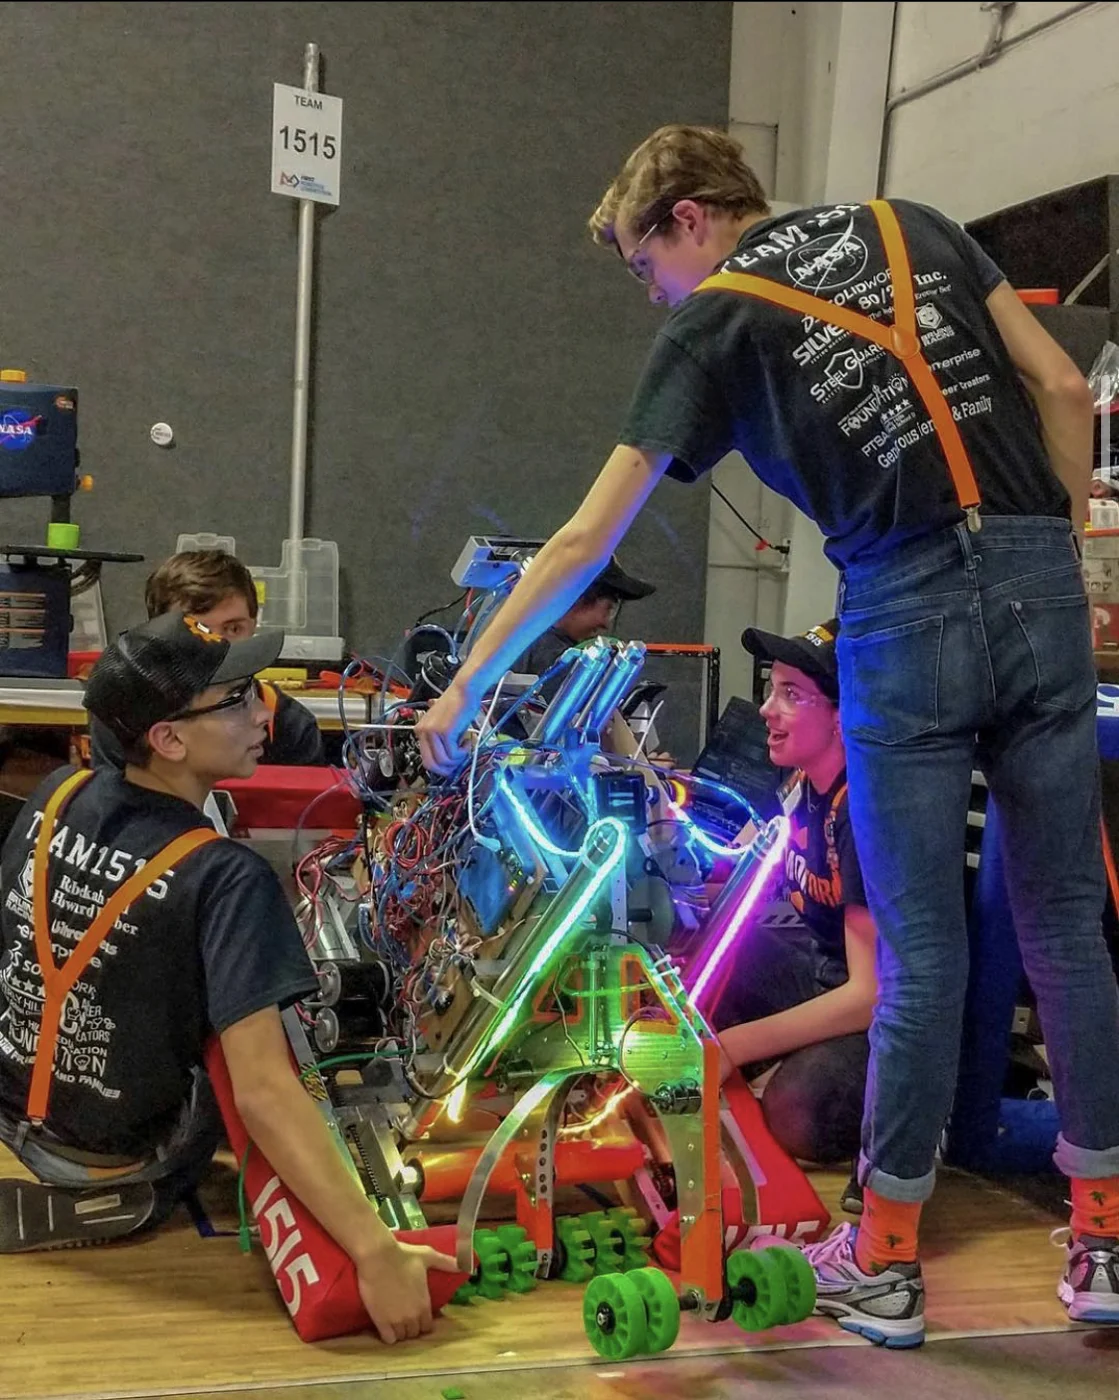
I led design across Teams 7173, 5124, 4512, and 1515, building intakes, shooters, lifts, and climbers.

05 / Team 7173

Lift & chassis

Founder & Head of Design

Angled view of Team 7173 robot showing the red bumper, lift structure, wiring, and chassis
TEAM 7173 Chassis, electronics & lift structure.
01 / Design & fabrication

From CAD to an assembled robot.

I developed floor intakes, one- and two-wheel flywheel shooters, and indexed reloading with PID-controlled feed. That work spans several teams and seasons.

I took mechanisms through CAD, CNC machining, lathe work, 3D printing, and assembly, including wiring and pneumatic integration. I also designed and iterated step, rope, and bar climbers, each with different demands on reach, weight, and load transfer.

My team roles

Team 7173
Founder & Head of Design
Team 5124
President & Head of Design
Team 4512
President & Head of Design
Team 1515
Vice President & Head of Design

February 22, 2018

Recognition in the
BC Legislature

Bob D’Eith on my role leading Garibaldi Secondary’s robotics team and my World Championships experience.

Workshop & mechanism photos

Experience & education

Sep 2024 – May 2025

Cellula Robotics

Mechanical Engineering Co-op

Autonomous underwater vehicles
Hardware design
I designed hydrogen fuel-cell hardware in SolidWorks, including vent-stack routing, mounts, and pressure-rated assemblies. For a hydrogen-oxygen diluter vessel, I worked through stress calculations, materials, vendor sourcing, and incoming test planning.
Thermal testing
I built an instrumented airflow and thermal test rig with GUI-controlled fans to measure catalyst heating at different input powers and compare thermal interfaces.
Data automation
I wrote Excel VBA tools to cross-reference PDM and ERP records across datasets containing millions of entries, replacing manual checks.

Expected Dec 2026

Simon Fraser
University

BASc, Mechatronic Systems Engineering

Controls, robotics and kinematics, machine learning, power electronics, and system modeling.

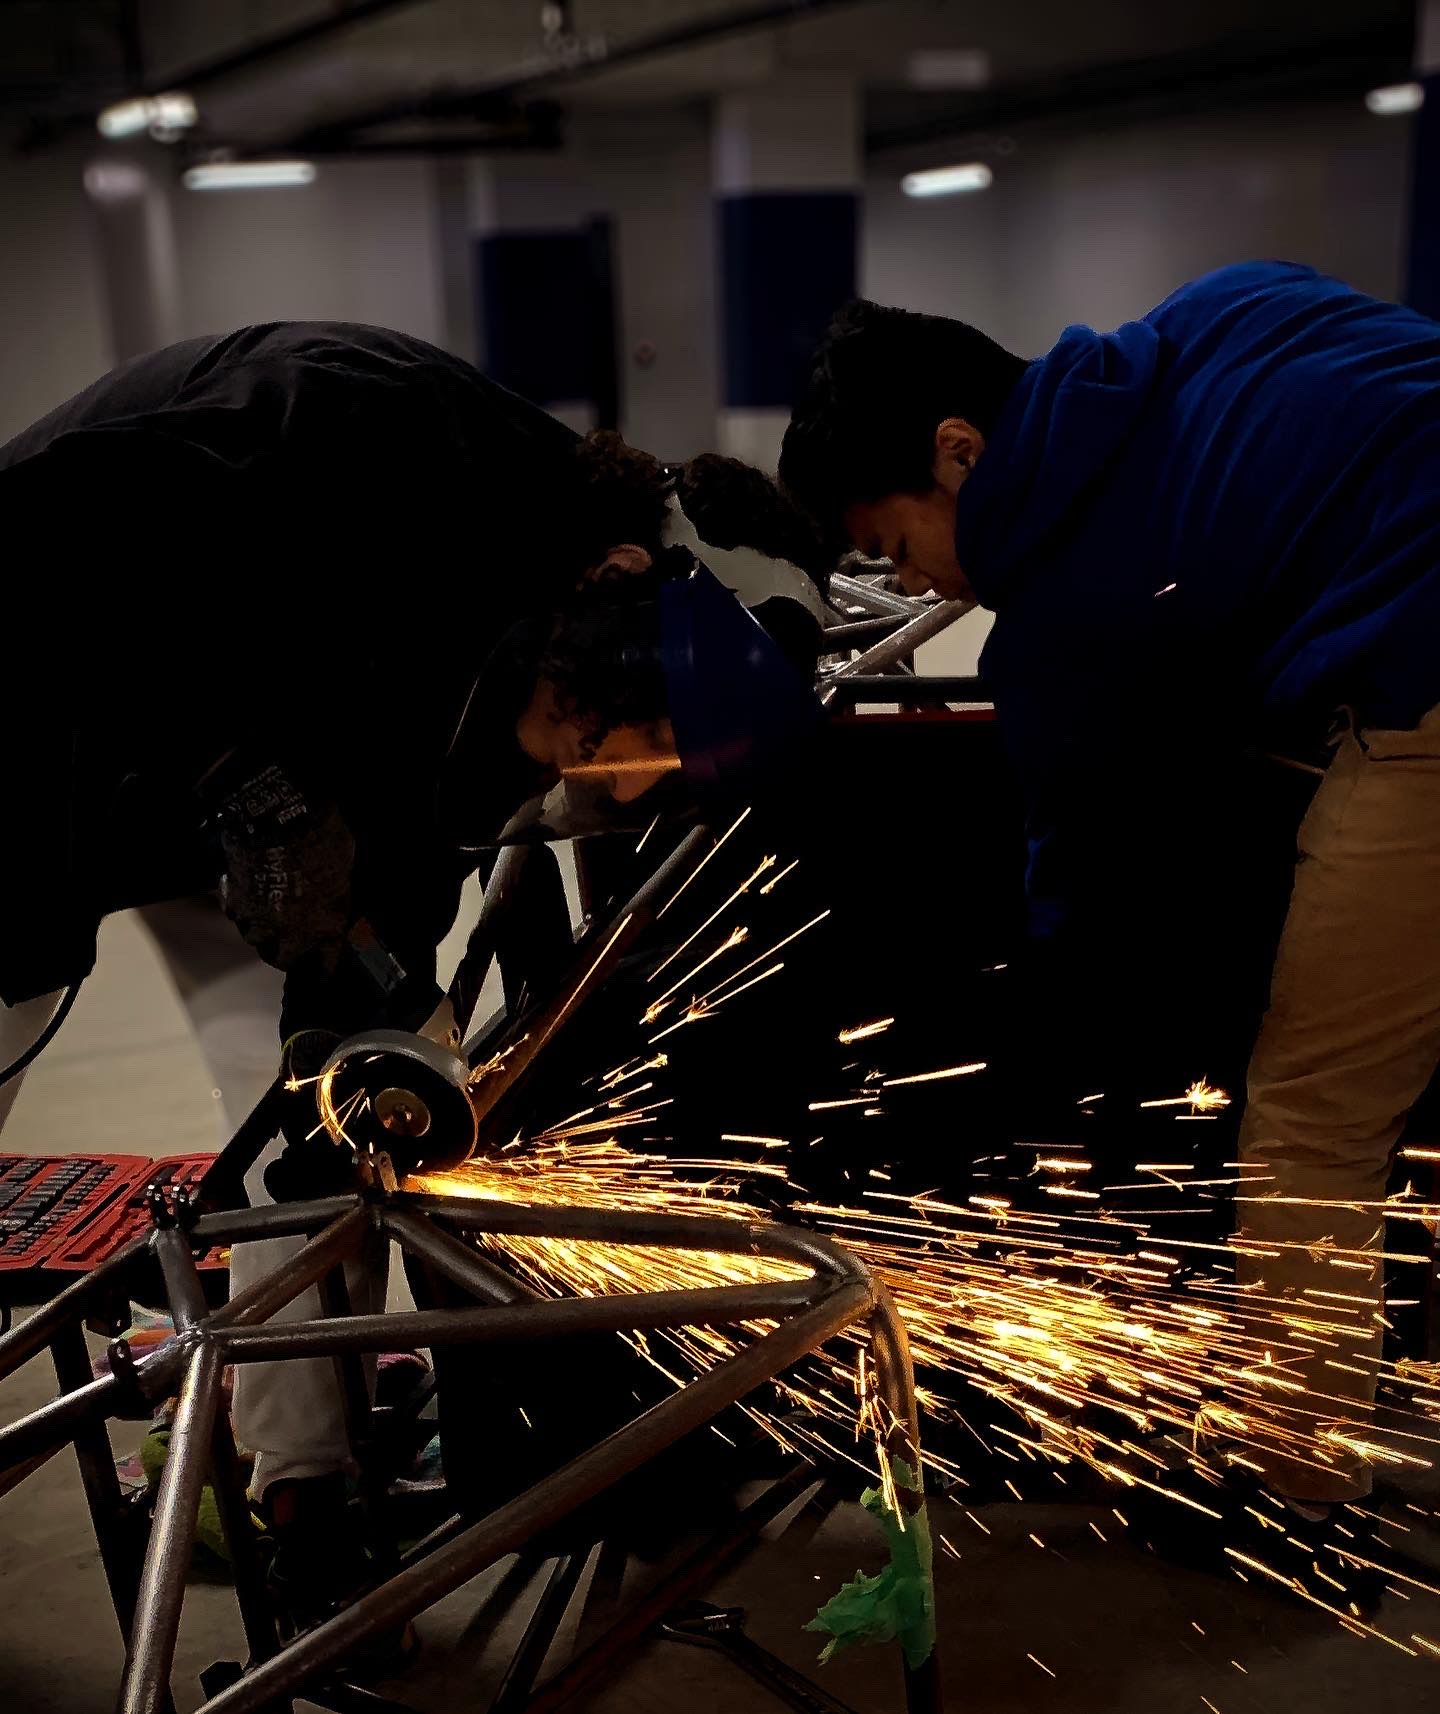
Formula SAE chassis fabrication, with team members cutting a tubular frame and sparks visible

Additional work

More engineering projects

  • Formula SAE design & fabrication
  • Machine learning & perception
  • 3-DOF chess robotic arm
  • Maze-solving robot
Explore all four projects

Recognition & support

Built with a team
& backed by community

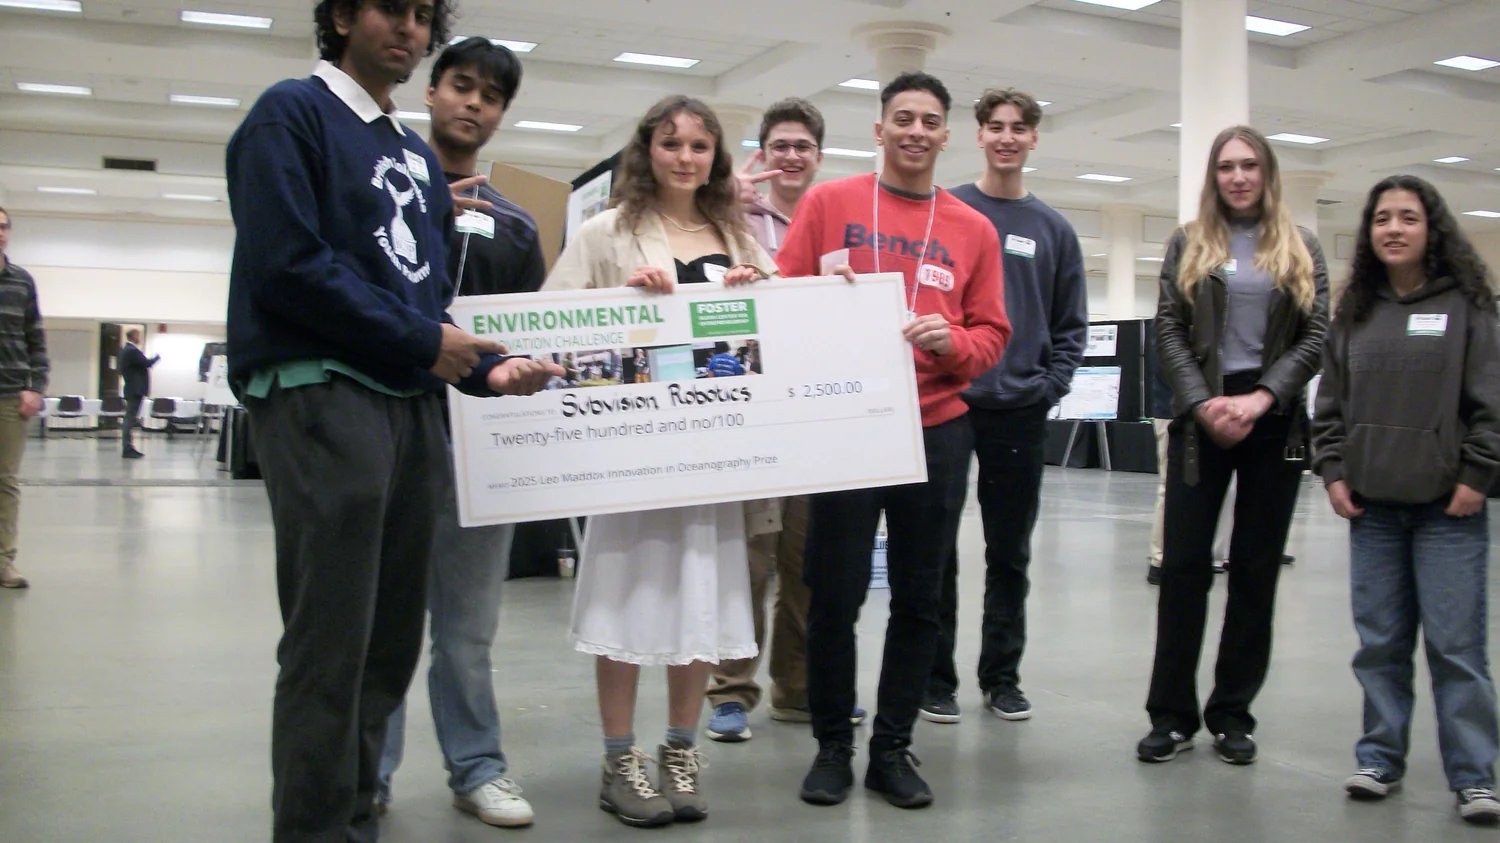
Subvision Robotics team holding an innovation in oceanography prize cheque at the 2025 Environmental Innovation Challenge
Subvision team · 2025 Environmental Innovation Challenge.

Subvision team

Individual & competition recognition

  • Triple A Leadership in Mechatronics
  • SFU Engineering CompetitionWinner 2024 · Second place 2025

Entrepreneurship program
Chang Institute eCo-op ↗ · Startup work term, mentorship, and academic co-op credit.

Open original ↗